

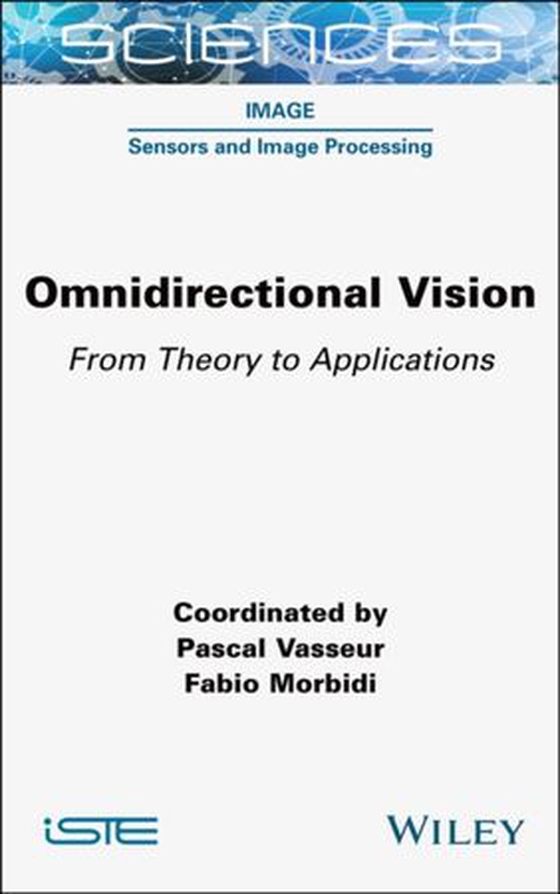
Pascal Vasseur
(redaktør)
,
Fabio Morbidi
(redaktør)
Omnidirectional Vision ebok
1773,-
Omnidirectional cameras, vision sensors that can capture 360° images, have in recent years had growing success in computer vision, robotics and the entertainment industry. In fact, modern omnidirectional cameras are compact, lightweight and inexpensive, and are thus being integrated in an increasing number of robotic platforms and consumer devices. However, the special format of output data requi…
Omnidirectional cameras, vision sensors that can capture 360° images, have in recent years had growing success in computer vision, robotics and the entertainment industry. In fact, modern omnidirectional cameras are compact, lightweight and inexpensive, and are thus being integrated in an increasing number of robotic platforms and consumer devices. However, the special format of output data requires tools that are appropriate for camera calibration, signal analysis and image interpretation.
This book is divided into six chapters written by world-renowned scholars. In a rigorous yet accessible way, the mathematical foundation of omnidirectional vision is presented, from image geometry and camera calibration to image processing for central and non-central panoramic systems. Special emphasis is given to fisheye cameras and catadioptric systems, which combine mirrors with lenses. The main applications of omnidirectional vision, including 3D scene reconstruction and robot localization and navigation, are also surveyed. Finally, the recent trend towards AI-infused methods (deep learning architectures) and other emerging research directions are discussed.
Ebok
1773,-

Undertittel
From Theory to Applications
Forlag
Wiley-ISTE
Utgitt
12.11.2026
Sjanger
Dokumentar og fakta
Språk
English
Format
epub
DRM-beskyttelse
LCP
ISBN
9781394256433
Omnidirectional cameras, vision sensors that can capture 360° images, have in recent years had growing success in computer vision, robotics and the entertainment industry. In fact, modern omnidirectional cameras are compact, lightweight and inexpensive, and are thus being integrated in an increasing number of robotic platforms and consumer devices. However, the special format of output data requires tools that are appropriate for camera calibration, signal analysis and image interpretation.
This book is divided into six chapters written by world-renowned scholars. In a rigorous yet accessible way, the mathematical foundation of omnidirectional vision is presented, from image geometry and camera calibration to image processing for central and non-central panoramic systems. Special emphasis is given to fisheye cameras and catadioptric systems, which combine mirrors with lenses. The main applications of omnidirectional vision, including 3D scene reconstruction and robot localization and navigation, are also surveyed. Finally, the recent trend towards AI-infused methods (deep learning architectures) and other emerging research directions are discussed.
Ingen vurderinger ennå
